179,00 €
+ 6,99 € Versand

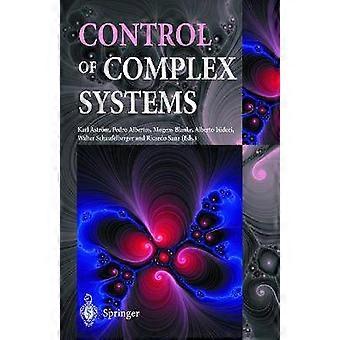
Control of Complex Systems
Verkauft von:

179,00 €

Auf Lager
+ 6,99 € Versand

14-Tage-Rückgabepolitik

Käuferschutz

Zahlungsmethoden:

  • Marke: Unbranded

Produktdetails

Produktdetails

Control of Complex Systems

1. Introduction. - 1. 1 Complex Systems and Control. - 1. 2 Complex Engineering Systems. - 1. 3 The Role of Feedback. - 1. 4 Dynamics and Control. - 1. 5 The Nature of Failures. - 1. 6 Research Challenges. - 1. 7 About the Book. - 2. Modeling Complex Physical Systems. - 2. 1 Introduction. - 2. 2 The Modelica Project. - 2. 3 Composition Diagrams. - 2. 4 Modelica Details. - 2. 5 Non-causal Modeling. - 2. 6 Advanced Modeling Features. - 2. 7 Standard Libraries. - 2. 8 Future Development. - 2. 9 Conclusions. - 3. Passivity-based Control of Non-linear Systems. - 3. 1 Introduction. - 3. 2 Passivity and Stability Analysis of Feedback Interconnections. - 3. 3 Feedback Passivity and Stabilization. - 3. 4 Euler-Lagrange Systems. - 3. 5 Disturbance Attenuation and R oo Control. - 4. An Introduction to Forwarding. - 4. 1 Introduction. - 4. 2 C1 Dissipative Systems. - 4. 3 C1 Dis sipative Systems via Reduction or Extension. - 4. 4 Exact Change of Coordinates. - 4. 5 Approximate Change of Coordinates. - 5. Iterative Identification and Control Design. - 5. 1 Introduction. - 5. 2 Youla Parametrization. - 5. 3 A Generic Two-degree of Freedom Controller. - 5. 4 Optimization of the Generic Scheme. - 5. 5 A New Closed-loop System Parametrization. - 5. 6 Asymptotic Variances for K-B-Parametrization. - 5. 7 Iterative Controller Refinement. - 5. 8 Robustness and Sensitivity. - 5. 9 Product Inequalities. - 6. Learning Control of Complex Systems. - 6. 1 Introduction. - 6. 2 Model Structures for Learning. - 6. 3 Control Structures for Learning. - 6. 4 Learning Paradigms. - 6. 5 A General Framework for On-line Learning. - 6. 6 Validation. - 6. 7 Conclusions. - 7. Software for Complex Controllers. - 7. 1 Introduction. - 7. 2 An Evolving Paradigm. - 7. 3 Emerging Software Concepts. - 7. 4 On to Standardization. - 7. 5 Sample Complex Software Controllers. - 7. 6 The Future of Software for Control. -8. Fault-tolerant Control Systems. - 8. 1 Introduction. - 8. 2 Basic Definitions. - 8. 3 Analysis of Fault Propagation. - 8. 4 Analysis of Structure. - 8. 5 Recoverability. - 8. 6 Autonomous Fault-tolerant Control. - 8. 7 An Example: Ship Propulsio. - 8. 8 Summary. - 9. Fault Detection and Isolation. - 9. 1 The Principle of Model-based Fault Diagnosis. - 9. 2 Signal-based FDI Approach. - 9. 3 Quantitative Model-based FDI Approach. - 9. 4 Qualitative Model-based FDI Approach. - 9. 5 Summary. - 10. Residual Generation for FDI in Non-linear Systems. - 10. 1 Introduction. - 10. 2 Algebraic Approach. - 10. 3 Geometric Approach. - 10. 4 Conclusion. - 11. Predictive Methods for FTC. - 11. 1 Introduction. - 11. 2 Predictive Control. - 11. 3 Embedding Fault Tolerance in Predictive Control. - 11. 4 Model Adaptation and Management. - 11. 5 Modifying Control Objectives. - 11. 6 Current Industrial Practice. - 11. 7 Conclusions. - 12. Three-tank Control Reconfiguration. - 12. 1 The Benchmark Problem. - 12. 2 Reconfigurability Analysis. - 12. 3 Reconfiguration Based on a Qualitative Model. - 12. 4 A Hybrid Approach to Reconfigurable Control. - 12. 5 A Multi-model-based Reconfigurable Control. - 12. 6 A Neural Observer-based Approach. - 12. 7 Conclusions. - 13. Ship Propulsion Control and Reconfiguration. - 13. 1 Introduction. - 13. 2 Ship Propulsion System. - 13. 3 Structural Analysis. - 13. 4 Fault Detection: A Fuzzy Observer Approach. - 13. 5 Fault Detection: Non-linear Approach - 1. - 13. 6 Fault Detection: Non-linear Approach - 2. - 13. 7 Reconfiguration Using Software Redundancy. - 13. 8 Reconfiguration Using Predictive Control. - 13. 9 Summary and Conclusions. - 14. Learning Control of Thermal Systems. - 14. 1 Introduction. - 14. 2 On Thermal System Learning Control. - 14. 3 Controlling Kiln Heat Processing. - 14. 4 Controlling Reheat Furnace Processes. - 14. 5 Hierarchical Control for Quality Ceramic Tiles. - 14. 6 Learning Control ofFBC Combustion. - 14. 7 Conclusions and Future Research. - 15. Vibration Control of High-rise Buildings. - 15. 1 Introduction. - 15. 2 Energy and Information. - 15. 3 Analytical Mechanics and HRB Modelling. - 15. 4 Disturbance Decoupling. - 15. 5 Passivity Based Control. - 15. 6 Engineering Constraints and Feedback. - 15. 7 Feedback Control and Testing. - 15. 8 Conclusions and Future Research. - 16. Control of Helicopters. - 16. 1 Introduction. - 16. 2 Project History. - 16. 3 The COSY Program. - 16. 4 Hardware System. - 16. 5 Software. - 16. 6 Design of the Autopilot. - 16. 7 Future Development. - 16. 8 Conclusions. - 17. Satellite Attitude Control. - 17. 1 Introduction to the Attitude Control Problem. - 17. 2 Fault-tolerant Control of the 0RSTED Satellite. - 17. 3 Stabilization of the Angular Velocity of a Rigid Body. - 17. 4 Optimal Slew Maneuvers via Geometric Control Theory. - 17. 5 Attitude Control using Magnetorquers as Sole Actuators. - 17. 6 Predictive Attitude Control of Small Satellites. - 17. 7 Attitude Determination without Sensor Redundancy. - 17. 8 Summary. - Appendix A. List of Contributors. - Appendix B. List of Abbreviations. - References. Language: English
  • Marke: Unbranded
  • Kategorie: Bildung
  • Künstler: Karl J. Aström
  • Format: Paperback
  • Verlag / Label: Springer
  • Sprache: English
  • Erscheinungsdatum: 2012/09/27
  • Seitenzahl: 482
  • Fruugo-ID: 337872348-741531648
  • ISBN: 9781447110743
Versprechen

Verkäufergarantie

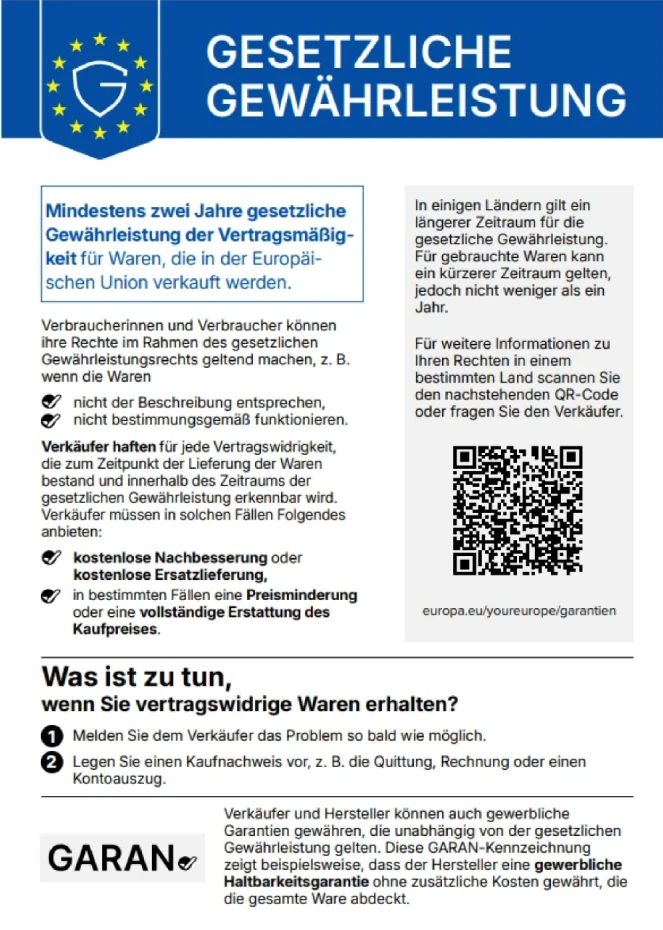
Gesetzliche Gewährleistung von 2 Jahren inklusive

Ihre Verbraucherrechte in der EU beinhalten eine kostenlose gesetzliche Gewährleistung von mindestens 2 Jahren

Gesetzliche Gewährleistung herunterladen
Lieferung

Lieferung

Versand innerhalb von 5 Tagen

  • STANDARD: 6,99 € - Lieferung zwischen Di. 13 Oktober 2026–Fr. 16 Oktober 2026

Versand von Vereinigtes Königreich.

Rücksendung

Rückgabe & Stornierung

Rückgabe

Wir tun unser Bestes, um dafür zu sorgen, dass die von Ihnen bestellten Produkte vollständig und gemäß Ihrer Spezifikationen an Sie geliefert werden. Wenn Sie allerdings eine unvollständige Bestellung oder Artikel erhalten, die sich von den bestellten unterscheiden, oder es einen anderen Grund gibt, warum Sie mit Ihrer Bestellung nicht zufrieden sind, können Sie die gesamte Bestellung oder einzelne darin enthaltenen Produkte zurücksenden und eine vollständige Rückerstattung für die Artikel erhalten.

Vollständige Rückgaberichtlinie ansehen

Stornierung

Sie haben das Recht, innerhalb von 14 Tagen nach Erhalt Ihrer Bestellung ohne Angabe von Gründen von Ihrem Kauf zurückzutreten. Um Ihr Widerrufsrecht einfach auszuüben, können Sie den Link „Meine Bestellung stornieren“ in der Fußzeile jeder Seite oder in Ihrem Fruugo-Konto unter „Bestellungen“ nutzen. Sobald Sie von Ihrem Widerrufsrecht Gebrauch gemacht haben, senden wir Ihnen eine Bestätigungs-E-Mail. Falls Ihre Bestellung bereits vom Händler versandt wurde, erhalten Sie von uns die notwendigen Rücksendeanweisungen, um eine schnelle Bearbeitung Ihrer Rückerstattung zu gewährleisten.

Vollständige Stornierungsbedingungen ansehen